VISUAL ESSAY / ARTIFICIAL INTELLIGENCE AND MACHINE LEARNING

Dense RL for AV Safety Validation

Reinforcement learning (RL) · Automated vehicle (AV)

FILM INDEX / JUMP TO AN ACT
FIELD GUIDE

Making Rare Dangers Visible

An autonomous vehicle may drive for an enormous distance before encountering a truly dangerous situation. Testing only under ordinary traffic would make evidence about rare failures painfully slow to collect. Yet filling a test with threats creates another problem: failures observed in that artificial setting cannot be read as the natural crash rate.

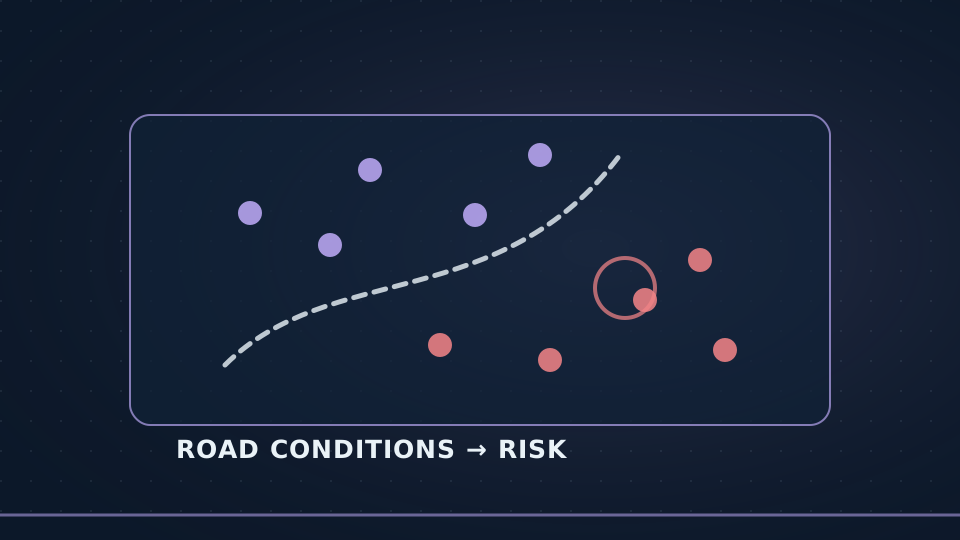
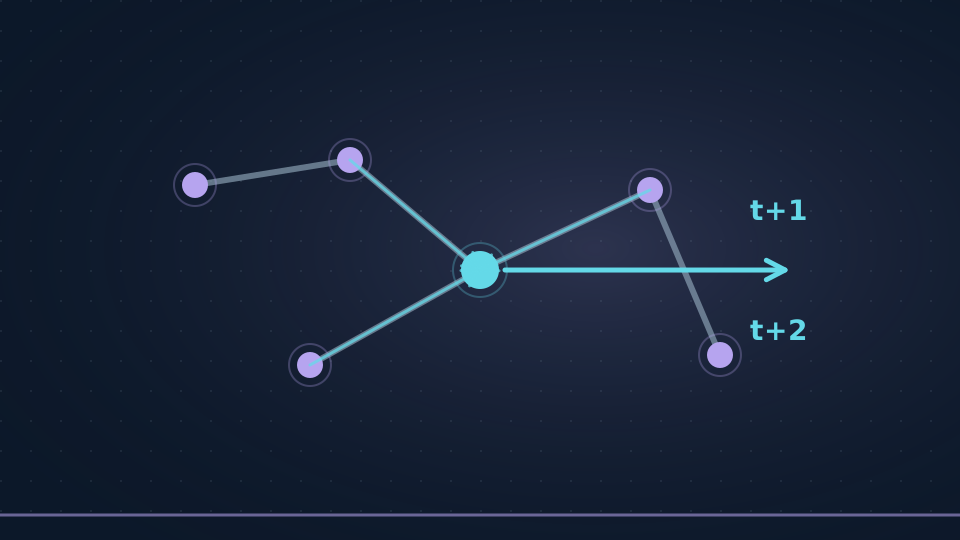
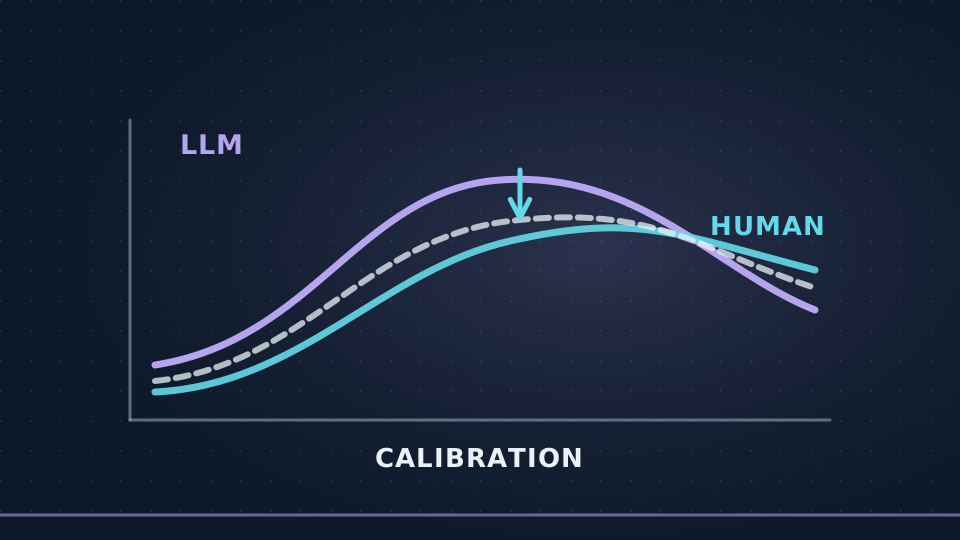
Sparse critical events are first linked into a denser learning signal. Nearly every surrounding vehicle then attempts a challenging maneuver, concentrating tests on situations that reveal how the automated vehicle responds. The following comparison shows why the changed sampling must be corrected before estimating real-world risk. Finally, the film contrasts the testing effort needed to reach the same precision. Its insight is a two-part discipline: create hard encounters efficiently, then account for how deliberately often those encounters were generated. More observed failures in a stress test can mean better evidence, not necessarily a less safe vehicle.